
VFD for tower crane
I. Overview
The tower crane is a lifting device with extensive application in construction site. The traditional controlling means usually employ AC wound-type electromotor serial resistance for starting and speed regulating. Because of long-term heavy load operation, frequent positive and negative revolving, the impulse current is rather great. Combing the bad environment of some working fields, the slip ring, carbon brush and contactor of the motor are often damaged. The phenomenon like burnt contact terminal of the contactor, flaming carbon brush, over burning of the motor and resistance usually occur. 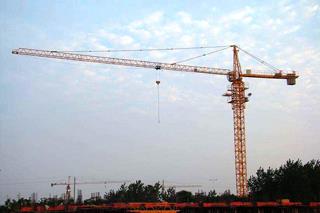 In addition, because of the complicated circuit, the bearing of the swing mechanism has to be exchanged usually. Since the main hoisting mechanism is mainly working on one shaft by two motors, the high-speed motor is still in working status while the low-speed motor is in braking status. They are always in the contradiction of one working and one braking. In addition, the mechanical shock of switching from high speed to low speed is great, the tooth striking phenomenon usually occurs. There was once the case that the product has been positioned and the worker has already hold the mooring rope, tooth striking phenomenon happened in switching from high speed into low speed, then the low-speed motor has brake failure. It is very dangerous. Occasionally, there is also axle breaking phenomenon. The high malfunction rate has big influence to the manufacturing, thus causing high maintenance quantity and cost.
Because the induction motor has incomparable advantages: Simple and solid structure, cheap price, and easy maintenance. So using the means of VFD dragging three-phase induction motor replaces the means of traditional speed regulating, can solve the problem of high failure rate of the tower crane fundamentally. Moreover, it has advanced technology and significant energy saving effect. It is the ideal transmission controlling device of the tower crane.
II. Working principle
- Cart operating organization: Drag the whole crane to have "horizontal" movement as the direction of the construction field. It is constituted by a motor, a braking device, a deceleration device and wheels.
- Trolley operating organization: Drag the lifting hook to have "vertical" movement as the direction of the crane span structure. It is constituted by a motor, a braking device, a deceleration device and wheels.
- Lifting organization: It is used to drag the heavy products to have lifting or descending movements. It is constituted by a motor, a deceleration device, a coiling block and a braking device. The large-scale crane (more than 10 tons) has two lifting organizations: "main hook" and "secondary hook". Normally, the "main hook" and "secondary hook" can't lift products at the same time.
- Swing mechanism: Drag the bridge arm to conduct revolving movement with the shaft as the center. For preventing from line deflection, it is mainly constituted by double motors, a deceleration mechanism and a braking device.
III. Technical requirement of VFD control tower crane
- The safe and reliable operation of the tower crane
- Can realize forward and reverse revolving, multi-stage speed operation, external reset of the frequency conversion malfunction, emergent stop of the frequency conversion malfunction to ensure safety.
- Frequency conversion starting, stopping and malfunction, ensure the effective movement of the mechanical brake and the safe operation of the device.
IV. Debugging parameters of ATO VFD for tower crane
| Function code | Name | Set value of main hook | Remark (use main hook only) |
| P0.00 | Selection of the frequency setting channel | 5 | Multi-stage speed operation setting |
| P0.02 | Selection of the operating command channel | 1 | Terminal command |
| P0.04 | Control mode | 0 | Without PG vector control |
| P0.10 | Acceleration time 1 | 1.5 | Unit (s) |
| P0.11 | Deceleration time 1 | 2 | Unit (s) |
| P0.15 | Torque rising | 10 | Unit (%) |
| P2.01 | Starting frequency | 3 | Unit (Hz) |
| P3.08 | Multistage speed | 10 | Unit (%), set according to customer requirements |
| P3.09 | Multistage speed 1 | 40 | |
| P3.11 | Multistage speed 3 | 60 | |
| P3.15 | Multistage speed 7 | 80 | |
| P4.34 | Multistage speed 14 | 50 | Unit (Hz) |
| P6.00 | Functional selection of terminal X1 | 1 | Forward revolving operation |
| P6.01 | Functional selection of terminal X2 | 2 | Reverse revolving operation |
| P6.02 | Functional selection of terminal X3 | 7 | Fault reset |
| P6.03 | Functional selection of terminal X4 | 12 | Multi-stage speed 1 |
| P6.04 | Functional selection of terminal X5 | 13 | Multi-stage speed 2 |
| P6.05 | Functional selection of terminal X6 | 14 | Multi-stage speed 3 |
| P6.06 | Functional selection of terminal X7 | 25 | Multi-stage speed 4 |
| P6.12 | Output selection of the relay (RA RB RC) | 4 | Frequency level detection FDT output |
| P6.13 | Output selection of the relay (RA RB RC) | 3 | Fault output |
| P6.19 | Frequency detection value (FDT electrical level) | 4 | Unit (Hz), set according to the field condition (for reference only) |
| P8.00 | Self-learning of the motor paramete | 2 | Set according to the field condition |
| P8.01 | Motor power | 15 | |
| P8.02 | Rated revolving speed of the motor | 0.6 | |
| P8.03 | Rated current of the motor | 40 |
Buying an ATO VFD for tower crane speed control now, 10 hp VFD, 25 hp VFD, 50 hp VFD...