Nema 23 2-phase Stepper Motor, 2.8A, 1.8 degree, 4 wires

$91.15
2-phase 4-wire stepper motor, size in Nema 23, holding torque of 1.89Nm, phase current of 2.8A , 1.8 deg. step angle(200 steps/revolution), high quality and manufacturer direct sale.
SKU: ATO-STEP-762328
Free Shipping
Delivery date: 6-12 days

Nema 23 Stepper motor, 2.8A phase curent, 1.89Nm in 76mm, 1.8 degree, manufacturer direct sale.

Specification

Electrical SpecificationModelATO57STH76-2804
Matched Driver ModelATODSP57(Click it to see more info)
Step Angle1.8°
Holding Torque1.89Nm
Rated Current/phase2.8A
Phase Resistance1.13Ω
Inductance3.6mH
Rotor Inertia440g-cm2
Physical SpecificationFrame Size57 x 57mm
Length76mm
Shaft DiameterΦ6.35mm
Shaft Length19mm
Motor Leads4
Weight1.1kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-20℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength500V AC for one minute
Shaft Radial Play0.02Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 23 Stepper Motor Dimensions: (Unit=mm)

NEMA 23 hybrid stepper motor dimensionsL Max=76mm

Nema 23 Stepper Motor Wiring Diagram
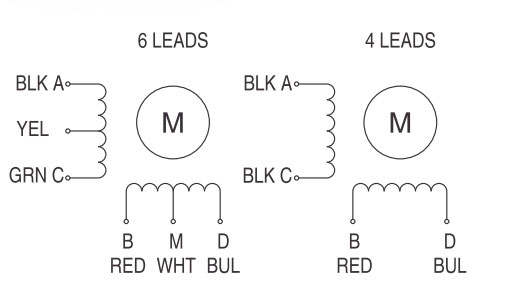
NEMA 23 hybrid stepper motor wiring diagram

Tips: Application of stepper motor into mine hoisting

Stepper motor features simple structure, large power, convenience in maintenance, high positioning accuracy, good reliability, small volume and as many as 32 choices for the drive system, low price, no accumulated location error, self-locking and low cost, so it is widely applied. Additionally, along with the application control of SCM using mature microcomputer technique, automatic control can be easily realized. Above characteristics completely meet the requirements of micro drive. Besides, automatic control of mine hoisting system and unattended duty hoisting system can be realized.
As for the control process of the stepper motor during mine hoisting, firstly, mine hoist reducer approaches the crawling stage and the velocity is reduced to about 3m/s, the electromagnetic valve is powered on with automatic control system. The electromagnetic valve rod overcomes the elastic force shift down of spring under the role of electromagnetic force so that the compressed air enters the cavity B from A and enters the gasbag clutch through hollow shaft of reducer, so that micro drive device can be connected with the host.
When the velocity is continuously reduced the crawling speed, the dynamic brake power of the main motor is cut off by controlling the circuit. The hoister crawls at stable low velocity from stepper motor drive. By hoisting the vessel to the end point to unload, control circuit to cut off the electromagnetic valve, so that the stepper motor is separated from main engine to complete the crawling process for once. Then, follow the next cycle, by improving and reducing the occurrence rate of accidents when unloading, the safety of coalmine production can be enhanced and foundation for automation production of the coalmine can be laid.

VFD Two-Wire Control Wiring with Push Button for Forward Motor

In this video we've guided you through how to do VFD control wiring with a self-lock push button switch to run the motor in forward direction. We've covered everything from wiring to programming and even a test run. So just watch it through and hope you'll find it informative and helpful.

Product reviews
Great value
5
Keran
Avatar
5/23/2022 7:13 PM
Received all three nema 23 stepper motors last week. Hooked them up and tested them. No issues found, very happy! Highly recommend! I will order more.
Was this review helpful? Yes No (0/0)
Write your review
  • Only registered users can write reviews
*
*
  • Bad
  • Excellent
*
*
*
*

Nema 23 Stepper motor, 2.8A phase curent, 1.89Nm in 76mm, 1.8 degree, manufacturer direct sale.

Specification

Electrical SpecificationModelATO57STH76-2804
Matched Driver ModelATODSP57(Click it to see more info)
Step Angle1.8°
Holding Torque1.89Nm
Rated Current/phase2.8A
Phase Resistance1.13Ω
Inductance3.6mH
Rotor Inertia440g-cm2
Physical SpecificationFrame Size57 x 57mm
Length76mm
Shaft DiameterΦ6.35mm
Shaft Length19mm
Motor Leads4
Weight1.1kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-20℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength500V AC for one minute
Shaft Radial Play0.02Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 23 Stepper Motor Dimensions: (Unit=mm)

NEMA 23 hybrid stepper motor dimensionsL Max=76mm

Nema 23 Stepper Motor Wiring Diagram

NEMA 23 hybrid stepper motor wiring diagram

Tips: Application of stepper motor into mine hoisting

Stepper motor features simple structure, large power, convenience in maintenance, high positioning accuracy, good reliability, small volume and as many as 32 choices for the drive system, low price, no accumulated location error, self-locking and low cost, so it is widely applied. Additionally, along with the application control of SCM using mature microcomputer technique, automatic control can be easily realized. Above characteristics completely meet the requirements of micro drive. Besides, automatic control of mine hoisting system and unattended duty hoisting system can be realized.
As for the control process of the stepper motor during mine hoisting, firstly, mine hoist reducer approaches the crawling stage and the velocity is reduced to about 3m/s, the electromagnetic valve is powered on with automatic control system. The electromagnetic valve rod overcomes the elastic force shift down of spring under the role of electromagnetic force so that the compressed air enters the cavity B from A and enters the gasbag clutch through hollow shaft of reducer, so that micro drive device can be connected with the host.
When the velocity is continuously reduced the crawling speed, the dynamic brake power of the main motor is cut off by controlling the circuit. The hoister crawls at stable low velocity from stepper motor drive. By hoisting the vessel to the end point to unload, control circuit to cut off the electromagnetic valve, so that the stepper motor is separated from main engine to complete the crawling process for once. Then, follow the next cycle, by improving and reducing the occurrence rate of accidents when unloading, the safety of coalmine production can be enhanced and foundation for automation production of the coalmine can be laid.

Product reviews
Great value
5
Keran
Avatar
5/23/2022 7:13 PM
Received all three nema 23 stepper motors last week. Hooked them up and tested them. No issues found, very happy! Highly recommend! I will order more.
Was this review helpful? Yes No (0/0)
Only registered users can write reviews