
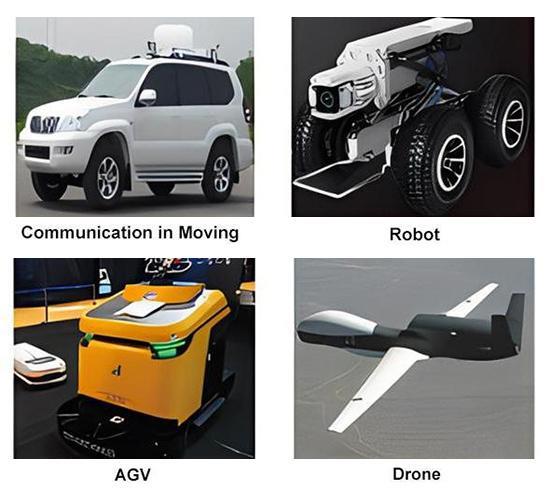
Miniature MEMS IMU sensor offers low cost solution for robotics/drones. 5V DC supply, 30mA current, triple M4 bolts installation. Four selectable connection options ensure easy integration into control systems.
Specification
| Model | ATO-IMUS700 | |
| Electrical | Supply Voltage | 5 V DC |
| Operating Current | 30 mA (40 mA max) | |
| Environmental & Reliability | Ingress Protection (IP) Rating | IP67 |
| Operating Temperature | -40 ~ +85 °C | |
| Storage Temperature | -55 ~ +100 °C | |
| Vibration Resistance | 2000 g | |
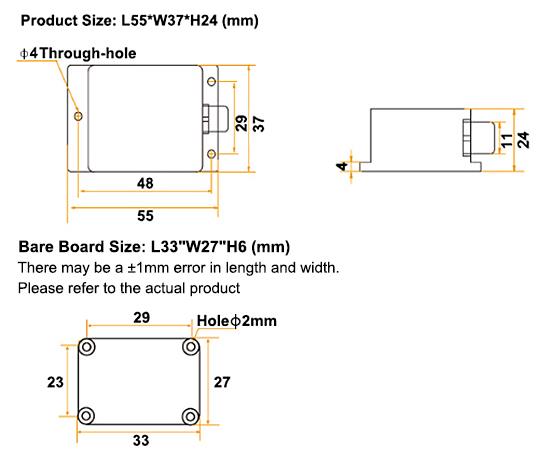
| Physical & Mechanical | Dimensions | L55 × W37 × H24 (mm) |
| Weight | 60 g | |
| Connector | Metal connector (Cable length 1.5m) | |
| Enclosure Material | Magnesium-Aluminum Alloy, Brushed & Anodized | |
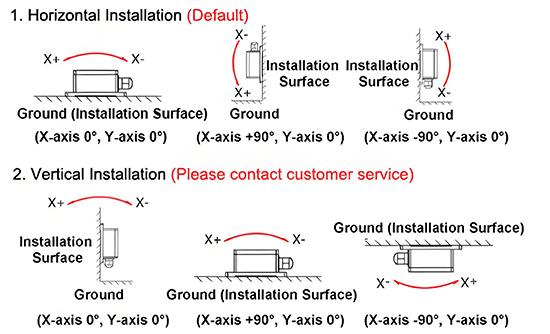
| Installation | Triple M4 Bolts | |
| Gyroscope Performance | Resolution | 0.1 °/sec |
| Measurement Range | ±2000 °/sec | |
| Bias Stability | 150 °/h | |
| ARW (Angular Random Walk) | 4.6 °/√h | |
| Noise Density | 0.01 °/s/√Hz | |
| Zero Offset Absolute Error | ±0.5 °/sec | |
| Accelerometer Performance | Measurement Range (X, Y, Z) | ±16 g |
| Resolution | 5 mg | |
| Bias Stability | ±20 mg | |
| Data Interface & Processing | Output Interface | RS232 / RS485 / TTL / CAN (Optional) |
| Filter Algorithm | High-performance Kalman filter | |
| Startup Delay | < 3 s | |
| Maximum Output Frequency | 100 Hz | |
| Serial Communication Baud Rate | 2400 to 115200 baud | |
| Digital Output Format | Binary High-Performance Protocol | |
Features
- Measurement capabilities: 6 axis IMU sensor measures acceleration and angular velocity.
- Power supply: The IMU for robotics/drone operates on a 5V DC power input.
- Environmental protection: Industrial IMU features IP67 ingress protection rating.
- Data processing: Integrates high-performance Kalman filter algorithm.
- Interface options: Supports RS232/RS485/TTL/CAN output interfaces.
- Physical dimensions: Small structure with L55×W37×H24 mm size.
Dimension
Installation
Application
Tips: How to optimize data output frequency for low-power drone applications with IMU?
To optimize IMU data output for low-power drones, strategically lower the output frequency via serial commands to reduce the processor's duty cycle and direct current draw. Complement this by decreasing the baud rate to minimize communication power, and leverage the IMU's internal Kalman filter to offload processing from the main controller, allowing it to sleep more. For maximum efficiency, implement dynamic scaling that switches between a low frequency for steady flight and a high frequency only during aggressive maneuvers, ensuring critical data accuracy while significantly extending battery life during extended missions.

High Precision Inertial Measurement Unit (IMU) Module

Wearable Wireless IMU Sensor with Bluetooth, 100Hz

6 Axis Industrial IMU Sensor, 3 Axis Gyro/Accelerometer

9 Axis MEMS IMU Sensor, 3 Axis Gyro/Magnetic/Accelerometer
