Nema 17 Stepper motor for 3D Printer, 12V 0.4A, 2 phase 6 wires

$66.46
The Nema 17 stepper motor is a professional and high precision stepper motor with 1.8 deg. step angle (200 steps/revolution), 2 phase 6 wires, high holding torque.
SKU: ATO-STEP-471704
*
Free Shipping
Delivery date: 6-12 days

12V 0.4A, 2 phase 6 wires Nema 17 stepper motor, with 1.8 deg. step angle (200 steps/revolution), is perfect for small robotics and automation projects. Cheap price and direct sale by manufacturer.

Specifications

Electrical SpecificationModelATO47-0406A
Matched the Driver ModelATODSP42 (Click it to see more info)
Step Angle1.8°
Holding Torque3.17kg-cm(44oz-in)
Voltage12V
Rated Current/phase0.4A
Phase Resistance30Ω
Inductance38mH
Rotor Inertia68g-cm2
Physical SpecificationFrame Size42 x 42mm
Length47mm
Shaft DiameterΦ5mm
Shaft Length22mm
Motor Leads6
Weight0.35kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-10℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength1Min. 500VAC·5mA
Shaft Radial Play0.06Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 17 Stepper Motor Dimension (Unit=mm)
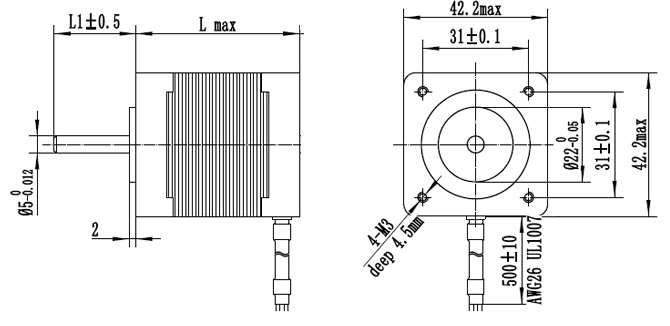
Nema 17 stepper motors dimension

L1=24mm, Lmax=47mm

Nema 17 Stepper Motor Wiring Diagram
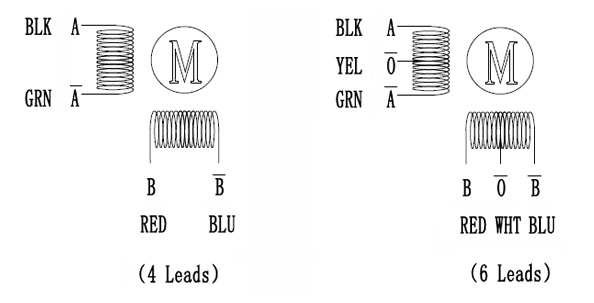
Nema 17 stepper motors wiring diagram

Tips: Why stepper motor cannot start at higher velocity and accompanying whistler?
The stepper motor can run normally at low velocity, and cannot start at certain higher velocity and accompanying whistler.
There is a technical parameter for the stepper motor: no-load start frequency. That is, the stepper motor can normally start pulse frequency under no-load. If the pulse frequency is higher than the value, the motor cannot normally start, the stalling or self-locking may occur. Under the circumstance of load, the start frequency shall be lower. The pulse frequency should have acceleration so that the motor rotates at high velocity. That is, the start frequency is low and then rises to the anticipated high frequency according to the acceleration (the motor runs at from low velocity to the higher one).
Except foregoing reasons, the reason for causing whistler may also be for big load. If the motor rotates at high velocity, the output torque of the motor will decreases. However, if the load requirement cannot be satisfied, stalling of motor will occur and whistler will be changed along with the change in frequency, to which the solution is to reduce the rotational velocity or replace for the motor with larger torque. Besides, after the motor rotates at high velocity and then stops, the transient whistler will be caused, which is resulted from chopping of phase current. It is only necessary to set the automatic semi-flow on the stepper driver board as effective.

Product reviews
Perfect Nema17 stepper motor
5
Freeb
Avatar
9/26/2021 12:46 AM
I bought these Nema 17 stepper motors for 3D printer. Upon arrival, they were in good condition (packaged well). I would purchase these again if needed.
Was this review helpful? Yes No (0/0)
High quality stepper motor
5
wxl
Avatar
5/23/2022 2:10 AM
I bought this Nema 17 stepper motors two months ago, plug and play with Ender 3 printer. Works as described. Comes with quality cables.
Was this review helpful? Yes No (0/0)
Quiet nema 17 stepper motor
5
Hacoy
Avatar
6/1/2022 2:52 AM
Pretty much exactly as the nema 17 stepper motor description states, these things work well and definitely are quieter than average. I would buy again.
Was this review helpful? Yes No (0/0)
Great replacement
5
Farrah
Avatar
6/27/2022 9:23 PM
I purchased this nema 17 stepper motor to replace the heavier motor on my machine. I can print faster now with less ringing due to the lower mass. The lower torque of this motor is not a problem.
Was this review helpful? Yes No (0/0)
Write your review
  • Only registered users can write reviews
*
*
  • Bad
  • Excellent
*
*
*
*

12V 0.4A, 2 phase 6 wires Nema 17 stepper motor, with 1.8 deg. step angle (200 steps/revolution), is perfect for small robotics and automation projects. Cheap price and direct sale by manufacturer.

Specifications

Electrical SpecificationModelATO47-0406A
Matched the Driver ModelATODSP42 (Click it to see more info)
Step Angle1.8°
Holding Torque3.17kg-cm(44oz-in)
Voltage12V
Rated Current/phase0.4A
Phase Resistance30Ω
Inductance38mH
Rotor Inertia68g-cm2
Physical SpecificationFrame Size42 x 42mm
Length47mm
Shaft DiameterΦ5mm
Shaft Length22mm
Motor Leads6
Weight0.35kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-10℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength1Min. 500VAC·5mA
Shaft Radial Play0.06Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 17 Stepper Motor Dimension (Unit=mm)

Nema 17 stepper motors dimension

L1=24mm, Lmax=47mm

Nema 17 Stepper Motor Wiring Diagram

Nema 17 stepper motors wiring diagram

Tips: Why stepper motor cannot start at higher velocity and accompanying whistler?
The stepper motor can run normally at low velocity, and cannot start at certain higher velocity and accompanying whistler.
There is a technical parameter for the stepper motor: no-load start frequency. That is, the stepper motor can normally start pulse frequency under no-load. If the pulse frequency is higher than the value, the motor cannot normally start, the stalling or self-locking may occur. Under the circumstance of load, the start frequency shall be lower. The pulse frequency should have acceleration so that the motor rotates at high velocity. That is, the start frequency is low and then rises to the anticipated high frequency according to the acceleration (the motor runs at from low velocity to the higher one).
Except foregoing reasons, the reason for causing whistler may also be for big load. If the motor rotates at high velocity, the output torque of the motor will decreases. However, if the load requirement cannot be satisfied, stalling of motor will occur and whistler will be changed along with the change in frequency, to which the solution is to reduce the rotational velocity or replace for the motor with larger torque. Besides, after the motor rotates at high velocity and then stops, the transient whistler will be caused, which is resulted from chopping of phase current. It is only necessary to set the automatic semi-flow on the stepper driver board as effective.

Product reviews
Perfect Nema17 stepper motor
5
Freeb
Avatar
9/26/2021 12:46 AM
I bought these Nema 17 stepper motors for 3D printer. Upon arrival, they were in good condition (packaged well). I would purchase these again if needed.
Was this review helpful? Yes No (0/0)
High quality stepper motor
5
wxl
Avatar
5/23/2022 2:10 AM
I bought this Nema 17 stepper motors two months ago, plug and play with Ender 3 printer. Works as described. Comes with quality cables.
Was this review helpful? Yes No (0/0)
Quiet nema 17 stepper motor
5
Hacoy
Avatar
6/1/2022 2:52 AM
Pretty much exactly as the nema 17 stepper motor description states, these things work well and definitely are quieter than average. I would buy again.
Was this review helpful? Yes No (0/0)
Great replacement
5
Farrah
Avatar
6/27/2022 9:23 PM
I purchased this nema 17 stepper motor to replace the heavier motor on my machine. I can print faster now with less ringing due to the lower mass. The lower torque of this motor is not a problem.
Was this review helpful? Yes No (0/0)
Only registered users can write reviews