Nema 17 Stepper motor, 4V 0.95A, 1.8 degree, 2 phase 6 wires

$64.92
High quality and favorable price Nema 17 4V, 0.95A, 2 phase 6 wires stepper motor which has 1.8 degree per step for smooth motion and a nice holding torque, direct sale by manufacturer.
SKU: ATO-STEP-3317095
*
Free Shipping
Delivery date: 6-12 days

This is a high precision 6-wire 2 phase stepper motor, 4V 0.95A, size in Nema 17, with 1.8 deg. step angle (200 steps/rev), body in 33mm, perfect for many applications.

Specifications

Electrical SpecificationModelATO33-0956A
Matched the Driver ModelATODSP42 (Click it to see more info)
Step Angle1.8°
Holding Torque1.58kg-cm(22oz-in)
Voltage4V
Rated Current/phase0.95A
Phase Resistance4.2Ω
Inductance4mH
Rotor Inertia35g-cm2
Physical SpecificationFrame Size42 x 42mm
Length33mm
Shaft DiameterΦ5mm
Shaft Length22mm
Motor Leads6
Weight0.22kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-10℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength1Min. 500VAC·5mA
Shaft Radial Play0.06Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 17 Stepper Motor Dimension (Unit=mm)
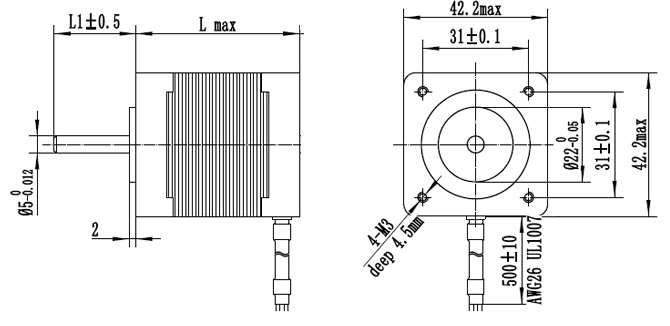
Nema 17 stepper motors dimension

L1=24mm, Lmax=33mm

Nema 17 Stepper Motor Wiring Diagram
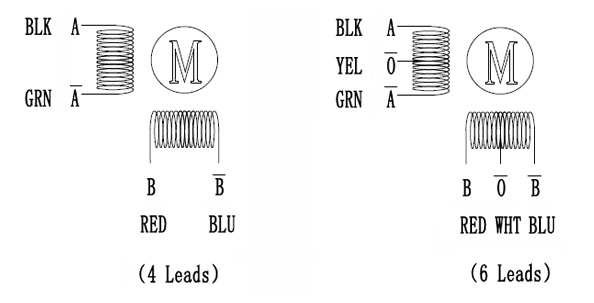
Nema 17 stepper motors wiring diagramTips: Whether the subdivision number of subdivided driver can represent accuracy?
4-phase hybrid stepper motor is generally started with 2-phase driver. Therefore, 4-phase motor can be used after connecting into 2-phase one through series or parallel connection. The series connection is generally used when the motor generally rotates at low velocity. At this time, the output current of driver should be 0.7 times of phase current of motor. Therefore, motor heating is small. By contrast, the parallel connection is generally used when the motor rotates at high velocity (also called high-velocity connection). At this time, the output current of the driver should be 1.4 times of the phase current of the motor. Therefore, the motor heating is large.

Product reviews
An excellent value
5
Chean
Avatar
5/23/2022 12:25 AM
These nema 17 stepper motors were quite in operation, and the holding torque seemed to be even a little better than spec. Overall, I am very pleased with the purchase, and will buy again for my next project.
Was this review helpful? Yes No (0/0)
Write your review
  • Only registered users can write reviews
*
*
  • Bad
  • Excellent
*
*
*
*

This is a high precision 6-wire 2 phase stepper motor, 4V 0.95A, size in Nema 17, with 1.8 deg. step angle (200 steps/rev), body in 33mm, perfect for many applications.

Specifications

Electrical SpecificationModelATO33-0956A
Matched the Driver ModelATODSP42 (Click it to see more info)
Step Angle1.8°
Holding Torque1.58kg-cm(22oz-in)
Voltage4V
Rated Current/phase0.95A
Phase Resistance4.2Ω
Inductance4mH
Rotor Inertia35g-cm2
Physical SpecificationFrame Size42 x 42mm
Length33mm
Shaft DiameterΦ5mm
Shaft Length22mm
Motor Leads6
Weight0.22kg
Technical ParametersStep Angle Accuracy±5% (full step, no load)
Resistance Accuracy±10%
Inductance Accuracy±20%
Temperature Rise80℃ Max. (rated current, 2 phase on)
Ambient Temperature-10℃~+50℃
Insulation Resistance100MΩ Min. 500VDC
Dielectric Strength1Min. 500VAC·5mA
Shaft Radial Play0.06Max. 450g
Shaft Axial Play0.08Max. 450g
Quality AssuranceWarranty Period12 months
CertificateCE, ROHs, ISO/SGS9001

Nema 17 Stepper Motor Dimension (Unit=mm)

Nema 17 stepper motors dimension

L1=24mm, Lmax=33mm

Nema 17 Stepper Motor Wiring Diagram

Nema 17 stepper motors wiring diagramTips: Whether the subdivision number of subdivided driver can represent accuracy?
4-phase hybrid stepper motor is generally started with 2-phase driver. Therefore, 4-phase motor can be used after connecting into 2-phase one through series or parallel connection. The series connection is generally used when the motor generally rotates at low velocity. At this time, the output current of driver should be 0.7 times of phase current of motor. Therefore, motor heating is small. By contrast, the parallel connection is generally used when the motor rotates at high velocity (also called high-velocity connection). At this time, the output current of the driver should be 1.4 times of the phase current of the motor. Therefore, the motor heating is large.

Product reviews
An excellent value
5
Chean
Avatar
5/23/2022 12:25 AM
These nema 17 stepper motors were quite in operation, and the holding torque seemed to be even a little better than spec. Overall, I am very pleased with the purchase, and will buy again for my next project.
Was this review helpful? Yes No (0/0)
Only registered users can write reviews