
2 phase Nema 34 bipolar stepper motor which has 1.8 degree per step for smooth motion and a nice holding torque, 4 wires, specified to have a maximum current of 4A, direct sale by manufacturer.
Specifications
| Basics | Model | ATO2160-4004A |
| Matched the Driver Model | ATODSP86 (Click it to see more info) | |
| Step Angle | 1.8° | |
| Length | 160mm | |
| Weight | 5.5kg | |
| Current | 4A | |
| Resistance | 1.4Ω | |
| Holding Torque | 12Nm | |
| Motor Leads | 4 | |
| Rotor Inertia | 4800g-cm2 | |
| Technical parameters | Step Angle Accuracy | ±5% (full step, no load) |
| Resistance Accuracy | ±10% | |
| Inductance Accuracy | ±20% | |
| Temperature Rise | 80℃Max. (rated current, 2 phase on) | |
| Ambient Temperature | -10℃~+50℃ | |
| Insulation Resistance | 100MΩ Min. 500VDC | |
| Dielectric Strength | 1Min. 500VAC·5mA | |
| Shaft Radial Play | 0.06Max. 450g | |
| Shaft Axial Play | 0.08Max. 450g |
Dimension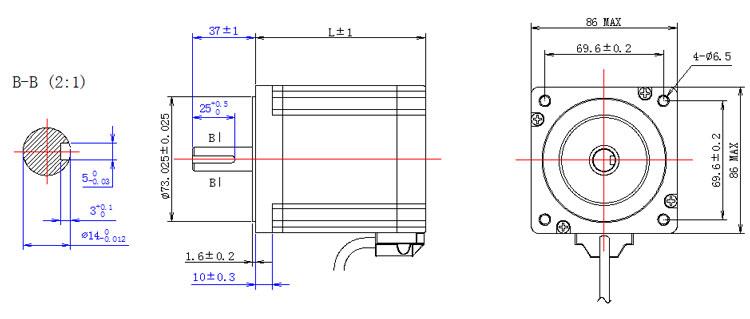
Motor Connection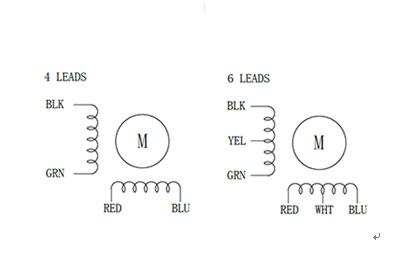
Tips: Why the stepper motor can be widely applied into the robot?
The advantages over using stepper motor for robot design:
- As for the motors with the same performance, the stepper motor is relatively cheaper.
- The stepper motor has longer service life than brushless electric machine, etc..
- It can accurately positioned without slipping or overshoot as digital motor.
- Drive module isn’t linear amplifier, which means fewer cooling fins, higher efficiency and higher reliability.
- Drive module is cheaper than linear amplifier.
- There is no expensive electronic component controlled by servo for the signal directly originates from MPU.
- Software is safe. As for the step-by-step pulse about board problem, if the software cannot work or is collapsed, the motor will be automatically ceased.
- As for the electronic driver fault-safe, in case of being locked due to the fault in amplifier, the motor cannot run. The motor still can run and may rotate at full speed in case of faults in servo driver.
- Whether the velocity control is accurate and repeatable (crystal control).
- If necessary, stepper motor rotates extremely slowly.
Due to the low-velocity torque device of stepper motor, the transmission is shorter, which means higher reliability, efficiency, smaller gap and lower cost. Just thanks to this feature, the robot is ideal for the requirement of most robots for short-distance motion is cycle period from acceleration to the low point.

Related products

2 phase CNC Nema 17 Stepper motor, 4V 1.2A, 6 wires
ATO-STEP-471712
$66.46
Brand new and good quality 2 phase 6 wires, Nema 17 stepper motor, resolution of 1.8 degree/step, torque of 44 oz/inch, manufacturer direct sale.

High Torque Nema 34 Stepper motor, 8A, 1.8 degree, 4 wires
ATO-STEP-21603408
$185.38
The Nema 34 stepper motor is a professional and high precision stepper motor with 1.8 deg. step angle (200 steps/revolution), 2 phase 4 wires, high holding torque, brand new direct sale by manufacturer.

Nema 17 Stepper motor, 12V 0.4A, 1.8 degree, 2 phase 6 wires
ATO-STEP-391704
$65.85
Nema 17 2 phase, 1.8 degree per step stepper motor with excellent quality and reasonable price, sell by manufacturer directly.

Nema 17 Stepper motor, 4V 0.95A, 1.8 degree, 2 phase 6 wires
ATO-STEP-3317095
$64.92
High quality and favorable price Nema 17 4V, 0.95A, 2 phase 6 wires stepper motor which has 1.8 degree per step for smooth motion and a nice holding torque, direct sale by manufacturer.