
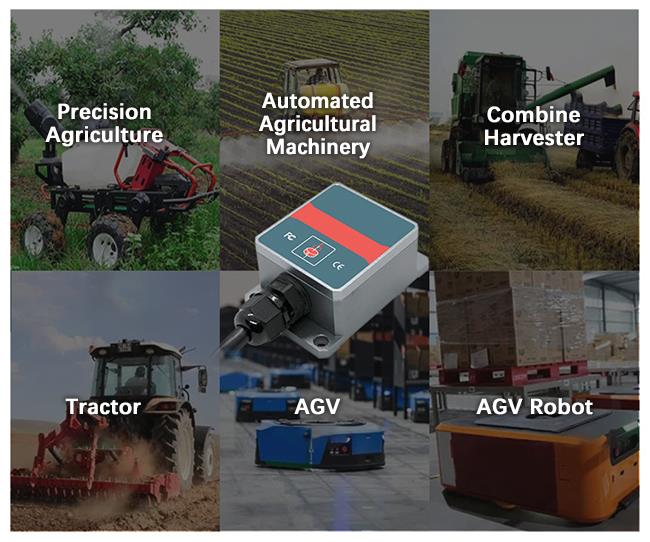
Mini electronic gyroscope provides ±180° measurement for AGV navigation. Output signal is CAN interface. This gyro accelerometer sensor is built for demanding AGV applications and achieves accurate positioning and stable control.
Specification
| Model | ATO-TL720D-C29W-AGM; ATO-TL720D-C29W-AGV; ATO-TL720D-C39W-AGM; ATO-TL720D-C39W-AGV |
| Azimuth Measurement Axis | Z-Axis Azimuth Angle (±180)° |
| Acquisition Bandwidth | >100 Hz |
| Resolution | 0.01° |
| Azimuth Accuracy | <0.1°/m |
| Position Accuracy | <2 mm/m (Calculated from angle) |
| Non-linearity | 0.1% of FS |
| Maximum Angular Velocity Range | 250°/s |
| Acceleration Range | ±4 g |
| Acceleration Resolution | 0.001 g |
| Acceleration Accuracy | 5 mg |
| Start-up Time | 200 ms |
| Supply Voltage | 9~36 VDC / 5 VDC (Optional) |
| Current | 30 mA (@12V) |
| Operating Temperature | -40 ~ +80°C |
| Storage Temperature | -40 ~ +85°C |
| Vibration | 5 g ~ 10 g |
| Shock | 200 g pk, 2 ms, ½ sine |
| Operating Life | 10 Years |
| Output Rate | 1 Hz ~ 100 Hz (Configurable) |
| Output Signal | CAN 2.0A / CAN 2.0B (Optional) |
| MTBF (Mean Time Between Failures) | ≥ 50,000 Hours |
| Insulation Resistance | ≥ 100 MΩ |
| Shock Resistance | 100 g @ 11 ms, Three Axes (Half-sine) |
| Vibration Resistance | 10 g_rms, 10 ~ 1000 Hz |
| Waterproof Rating | IP67 |
| Weight | 90 g (Excluding Cable) |
Note: The start-up time for AGV applications is 5 seconds at rest.
Features
- Compact and lightweight design: Small gyro sensor features compact housing with 90g weight for easy AGV integration.
- Superior temperature stability: High precision MEMS gyroscope maintains stable performance across -40°C to +80°C range with 10-year lifespan.
- Real-time angular output: Super gyrometer sensor provides ±180° azimuth and angular rate data for precise AGV navigation.
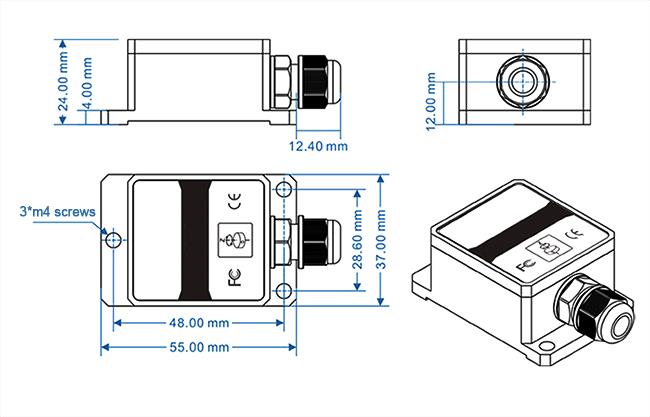
Dimension
Installation
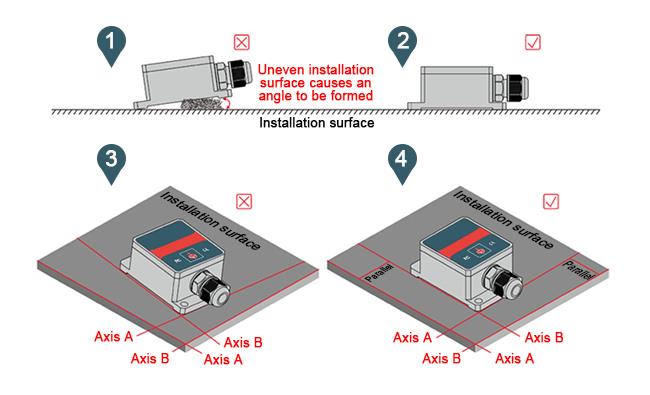
The gyroscope should be mounted as close to the center of the object being measured as possible to minimize the impact of linear acceleration on measurement accuracy. The mounting surface should be kept parallel to the object being measured to minimize the effects of dynamic forces and acceleration on the inclinometer. Improper installation can lead to measurement errors, especially regarding the "surface" and "line":
- Ensure the digital gyro mounts securely and flatly to avoid measurement errors from uneven surfaces. See Figures ① and ②.
- The electric gyro's axis must be parallel to the measured axis, with minimal angle between the two axes. See Figures ③ and ④.
Application
Tips: What operational conditions should be avoided to maintain the gyroscope sensor's measurement accuracy?
To ensure optimal performance, avoid exposing the 6 axis gyroscope to severe shocks, vibrations, or angular velocities exceeding 300°/s. This includes preventing violent shaking, installing damping mounts when vibration sources are unavoidable, and refraining from sudden acceleration, abrupt stops, and sharp turns that surpass this limit.

3D Electronic Gyroscope Sensor, 1 Axis, ±180°, RS232/RS485/TTL

Angular Velocity Output Gyroscope Sensor, ±50°/ ±150°/ ±300°

Current (Voltage) Output Gyroscope Sensor, ±50°/ ±150°/ ±300°
